EEEE1039 · Construction project · 2025
Robotic vehicle coursework
An early course project in sensing, embedded control and vehicle integration, progressing from Arduino control exercises to a Raspberry Pi vision prototype.
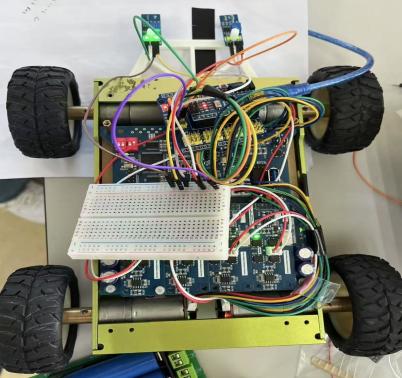
Control and integration
The recovered viva slides document optical-sensor calibration, two-sensor bang-bang line following, and an eight-channel PID line-following task. An encoder and LCD interface support parameter tuning and motion-state display.
Other exercises cover nRF24L01+ and HC-06 communication, MPU-6050 sensing, logic gates and PWM. These are coursework stages and should not be read as a single final vehicle with every function operating simultaneously.
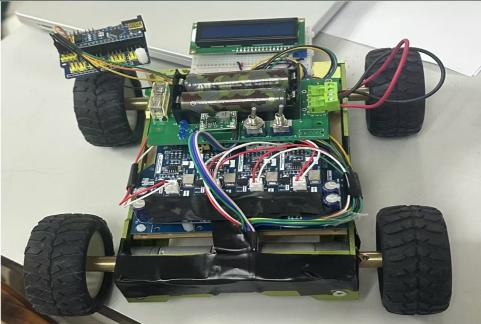
The Raspberry Pi stage
The Group 18 poster describes a Raspberry Pi vehicle combining OpenCV image processing, an HC-SR04 distance sensor, an SG90 servo and a camera. The planning documents and later viva slides provide supporting context for the group’s staged work.
This coursework vehicle is separate from the FURP 2025 transformable land–air robot. The recovered group documents establish participation and team activities; they do not provide a complete record of individual task ownership.
Original record
Sources: Group 18 Raspberry Pi Project poster, Session III–IV viva slides, G18 Planning Project 2, G18S3Planning and Session IV Planning. Original student numbers are omitted from this public page.
The selected photographs are original hardware images from the course viva slides, shown at their original proportions.