Robotics & perception
Robot–Elevator Interaction
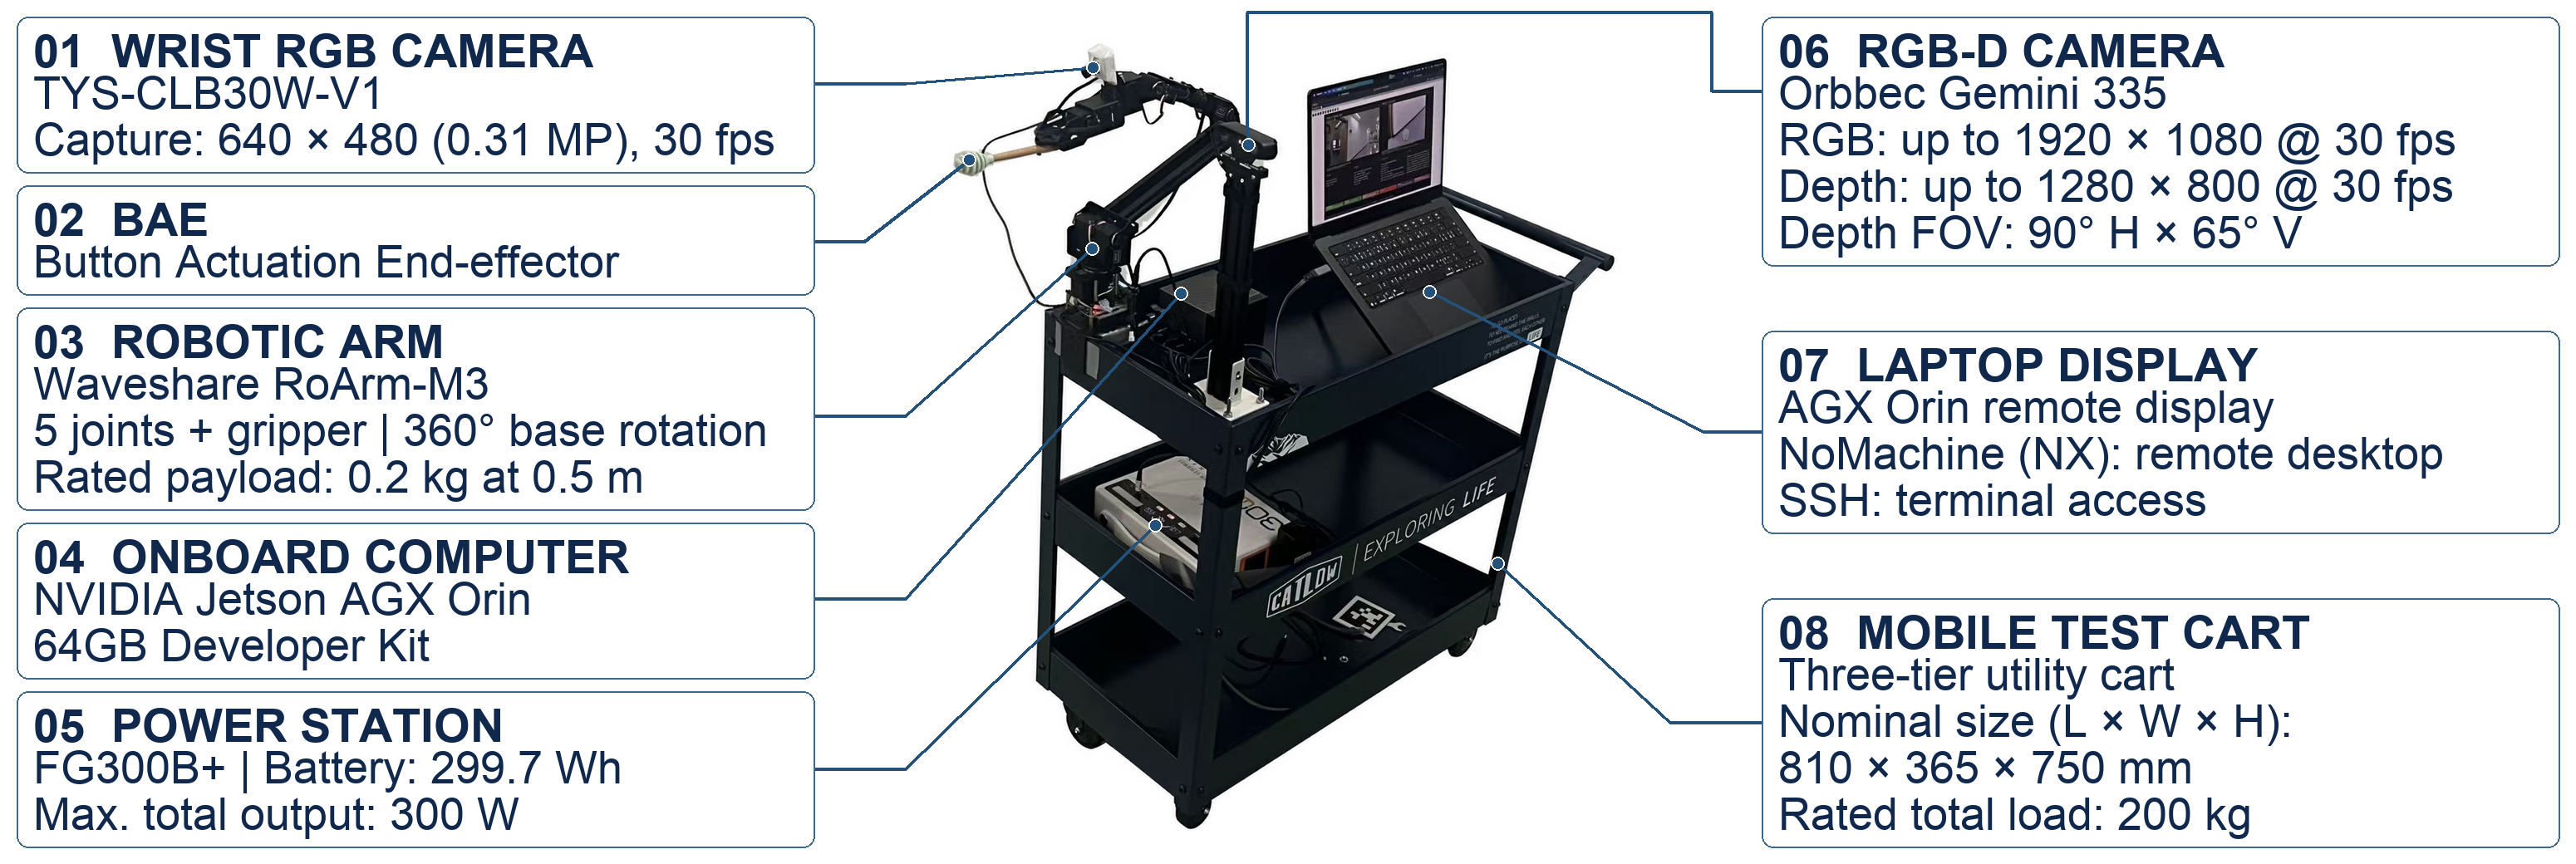
Teaching a robot
to read the lift.
Recognising a button is one problem. Choosing the right one, locating it in 3D, and approaching it safely is another. This project connects those steps in a staged, guarded workflow.
RGB-D · OpenCV · calibration · robot arm
My contribution: staged perception, RGB-D localisation, calibration, and guarded arm integration within a collaborative research project.
Open the project notes
The pipeline combines button detection, HOG+SVM classification, semantic target selection, RGB-D localisation, calibration, and guarded robot-arm interaction.
Evaluation: 0.9963 macro-F1 on 379 labelled crops; 85.1% offline request-level target selection accuracy. The two qualitative demonstrations are separate from evidence of generalised deployment.
IHCI 2026 · Paper 105 · accepted for oral presentation