FURP 2025 · Team research prototype
Transformable land–air robot
A FURP 2025 team adaptation of Michael Rechtin’s Transforming Quadcopter, combining ground locomotion and quadrotor flight.
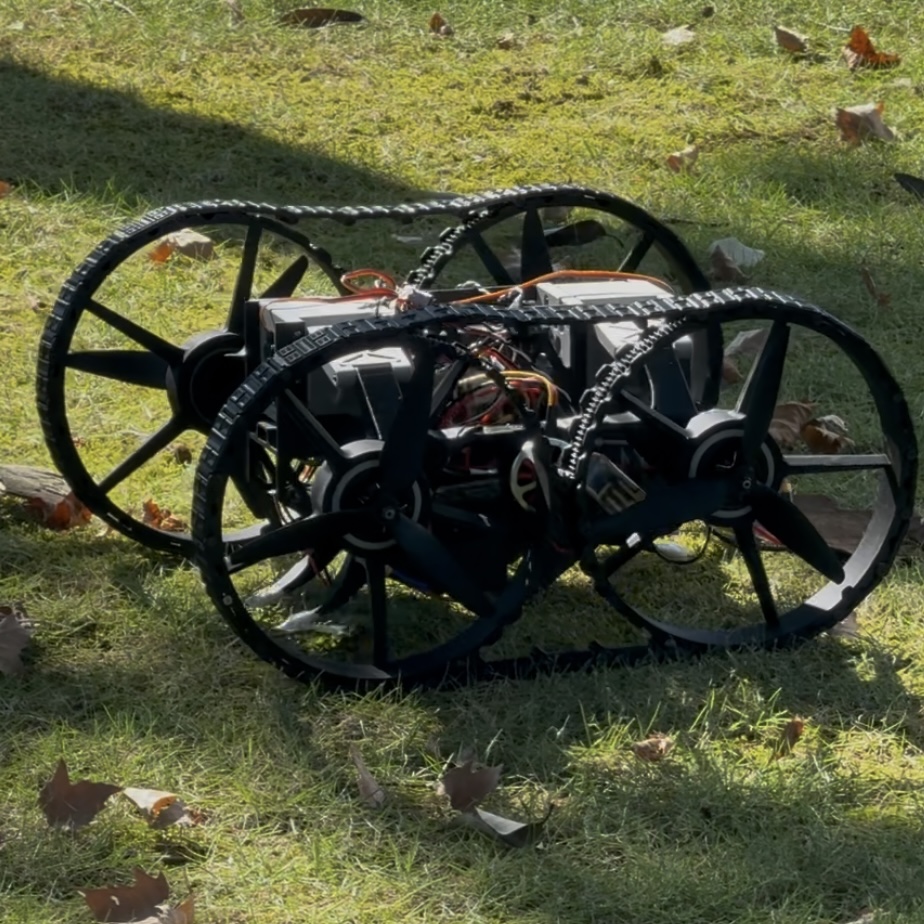
Design basis and team adaptation
The prototype adapts Michael Rechtin’s Transforming Quadcopter, introduced in his YouTube video Building a Real Life Transformer. The team adapted the design and integrated the mechanical assembly, motion control and embedded systems for the FURP project.
The team’s Transformer Quadcopter poster describes two ground-drive motors, four propeller motors, two servos and two linear actuators. A Pixhawk 2.4.8 controller handles the flight system, while separate RC control supports the ground system and manual transformation.
My work within the team focused on mechanical modifications, motion control and embedded-system debugging. The prototype brought together structure, actuator travel, power distribution and control interfaces.
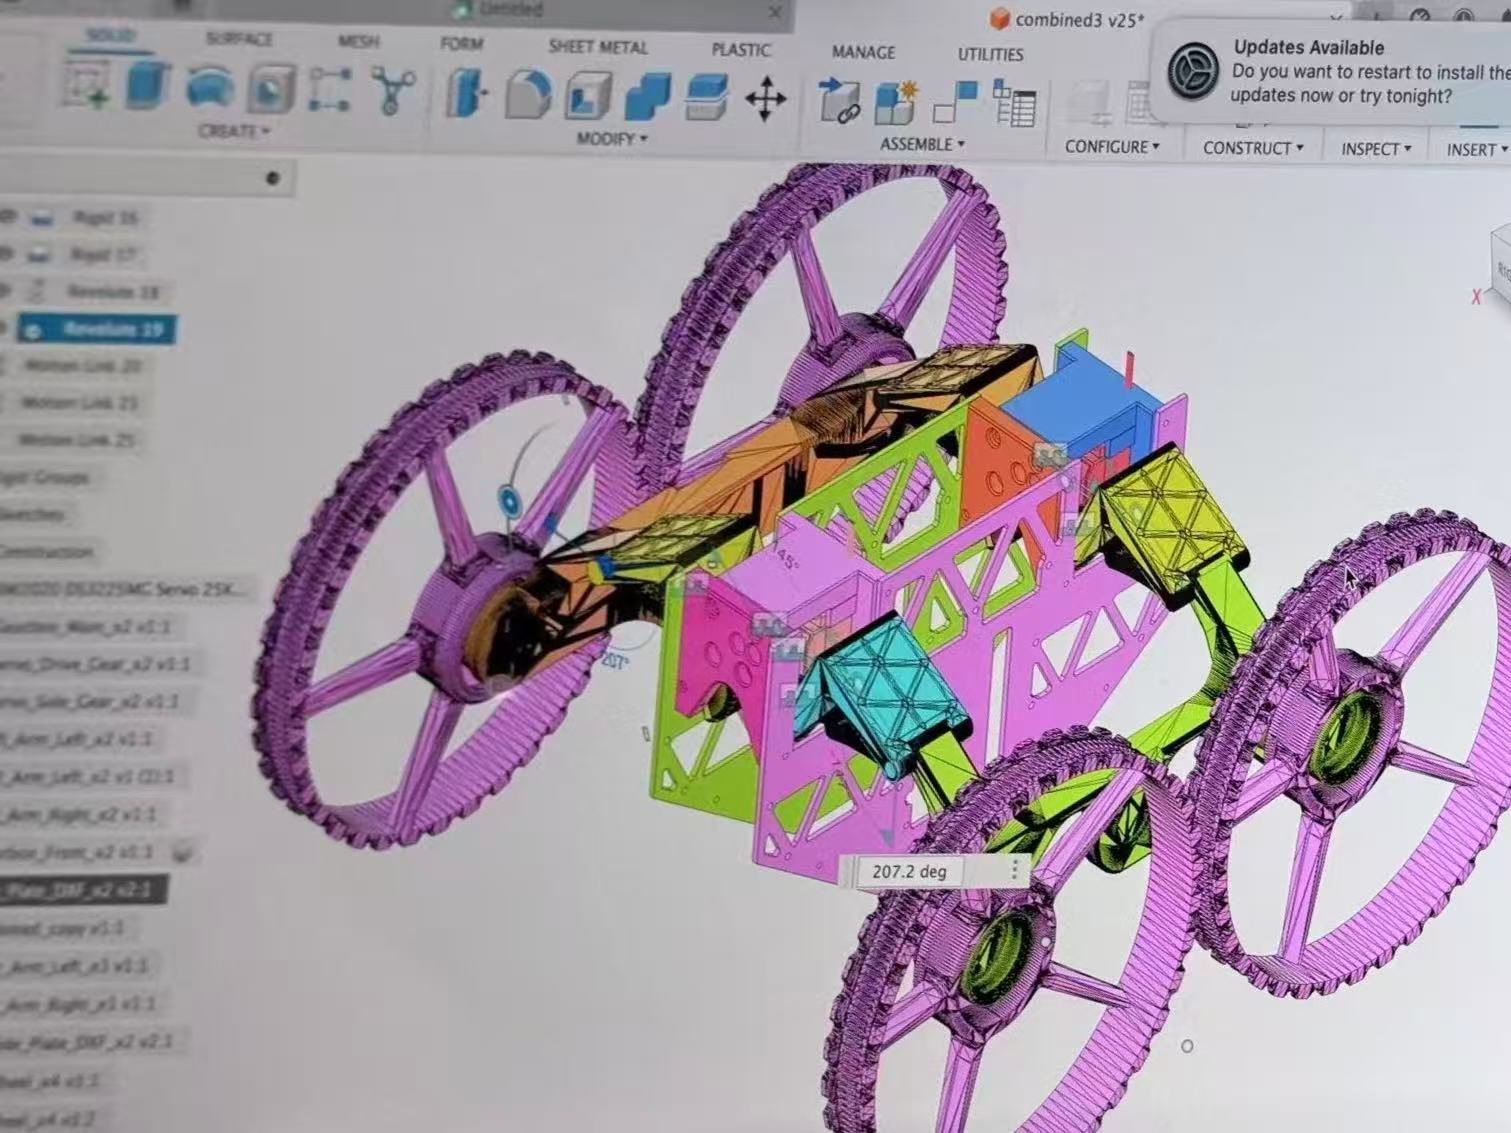
Prototype observations
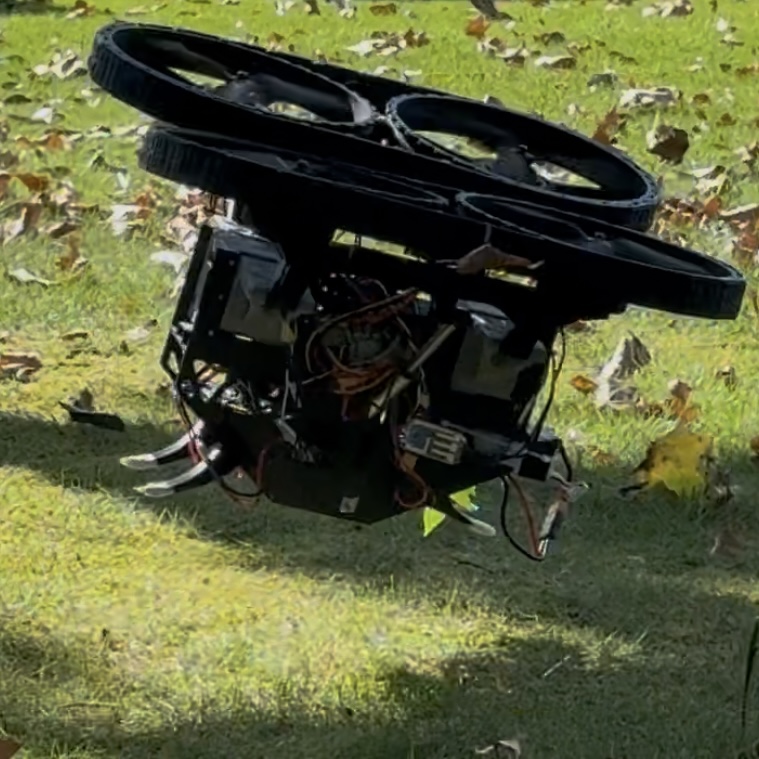
The poster reports ground testing and low-altitude lift-off and landing. These are team-reported observations; the recovered material does not establish repeatable autonomous flight. Visual navigation, SLAM and adaptive autonomous mode switching are listed as future work.
Original record
Source: Transformer Quadcopter, FURP 2025 team poster v9. Supervisor: Dr Chiew-Foong Kwong; advisor: Fuhua Jia. The original author list is retained above. A final written report has not been recovered.
The figures here are complete image assets extracted from the poster. The full poster contains student numbers and is kept in the private archive.